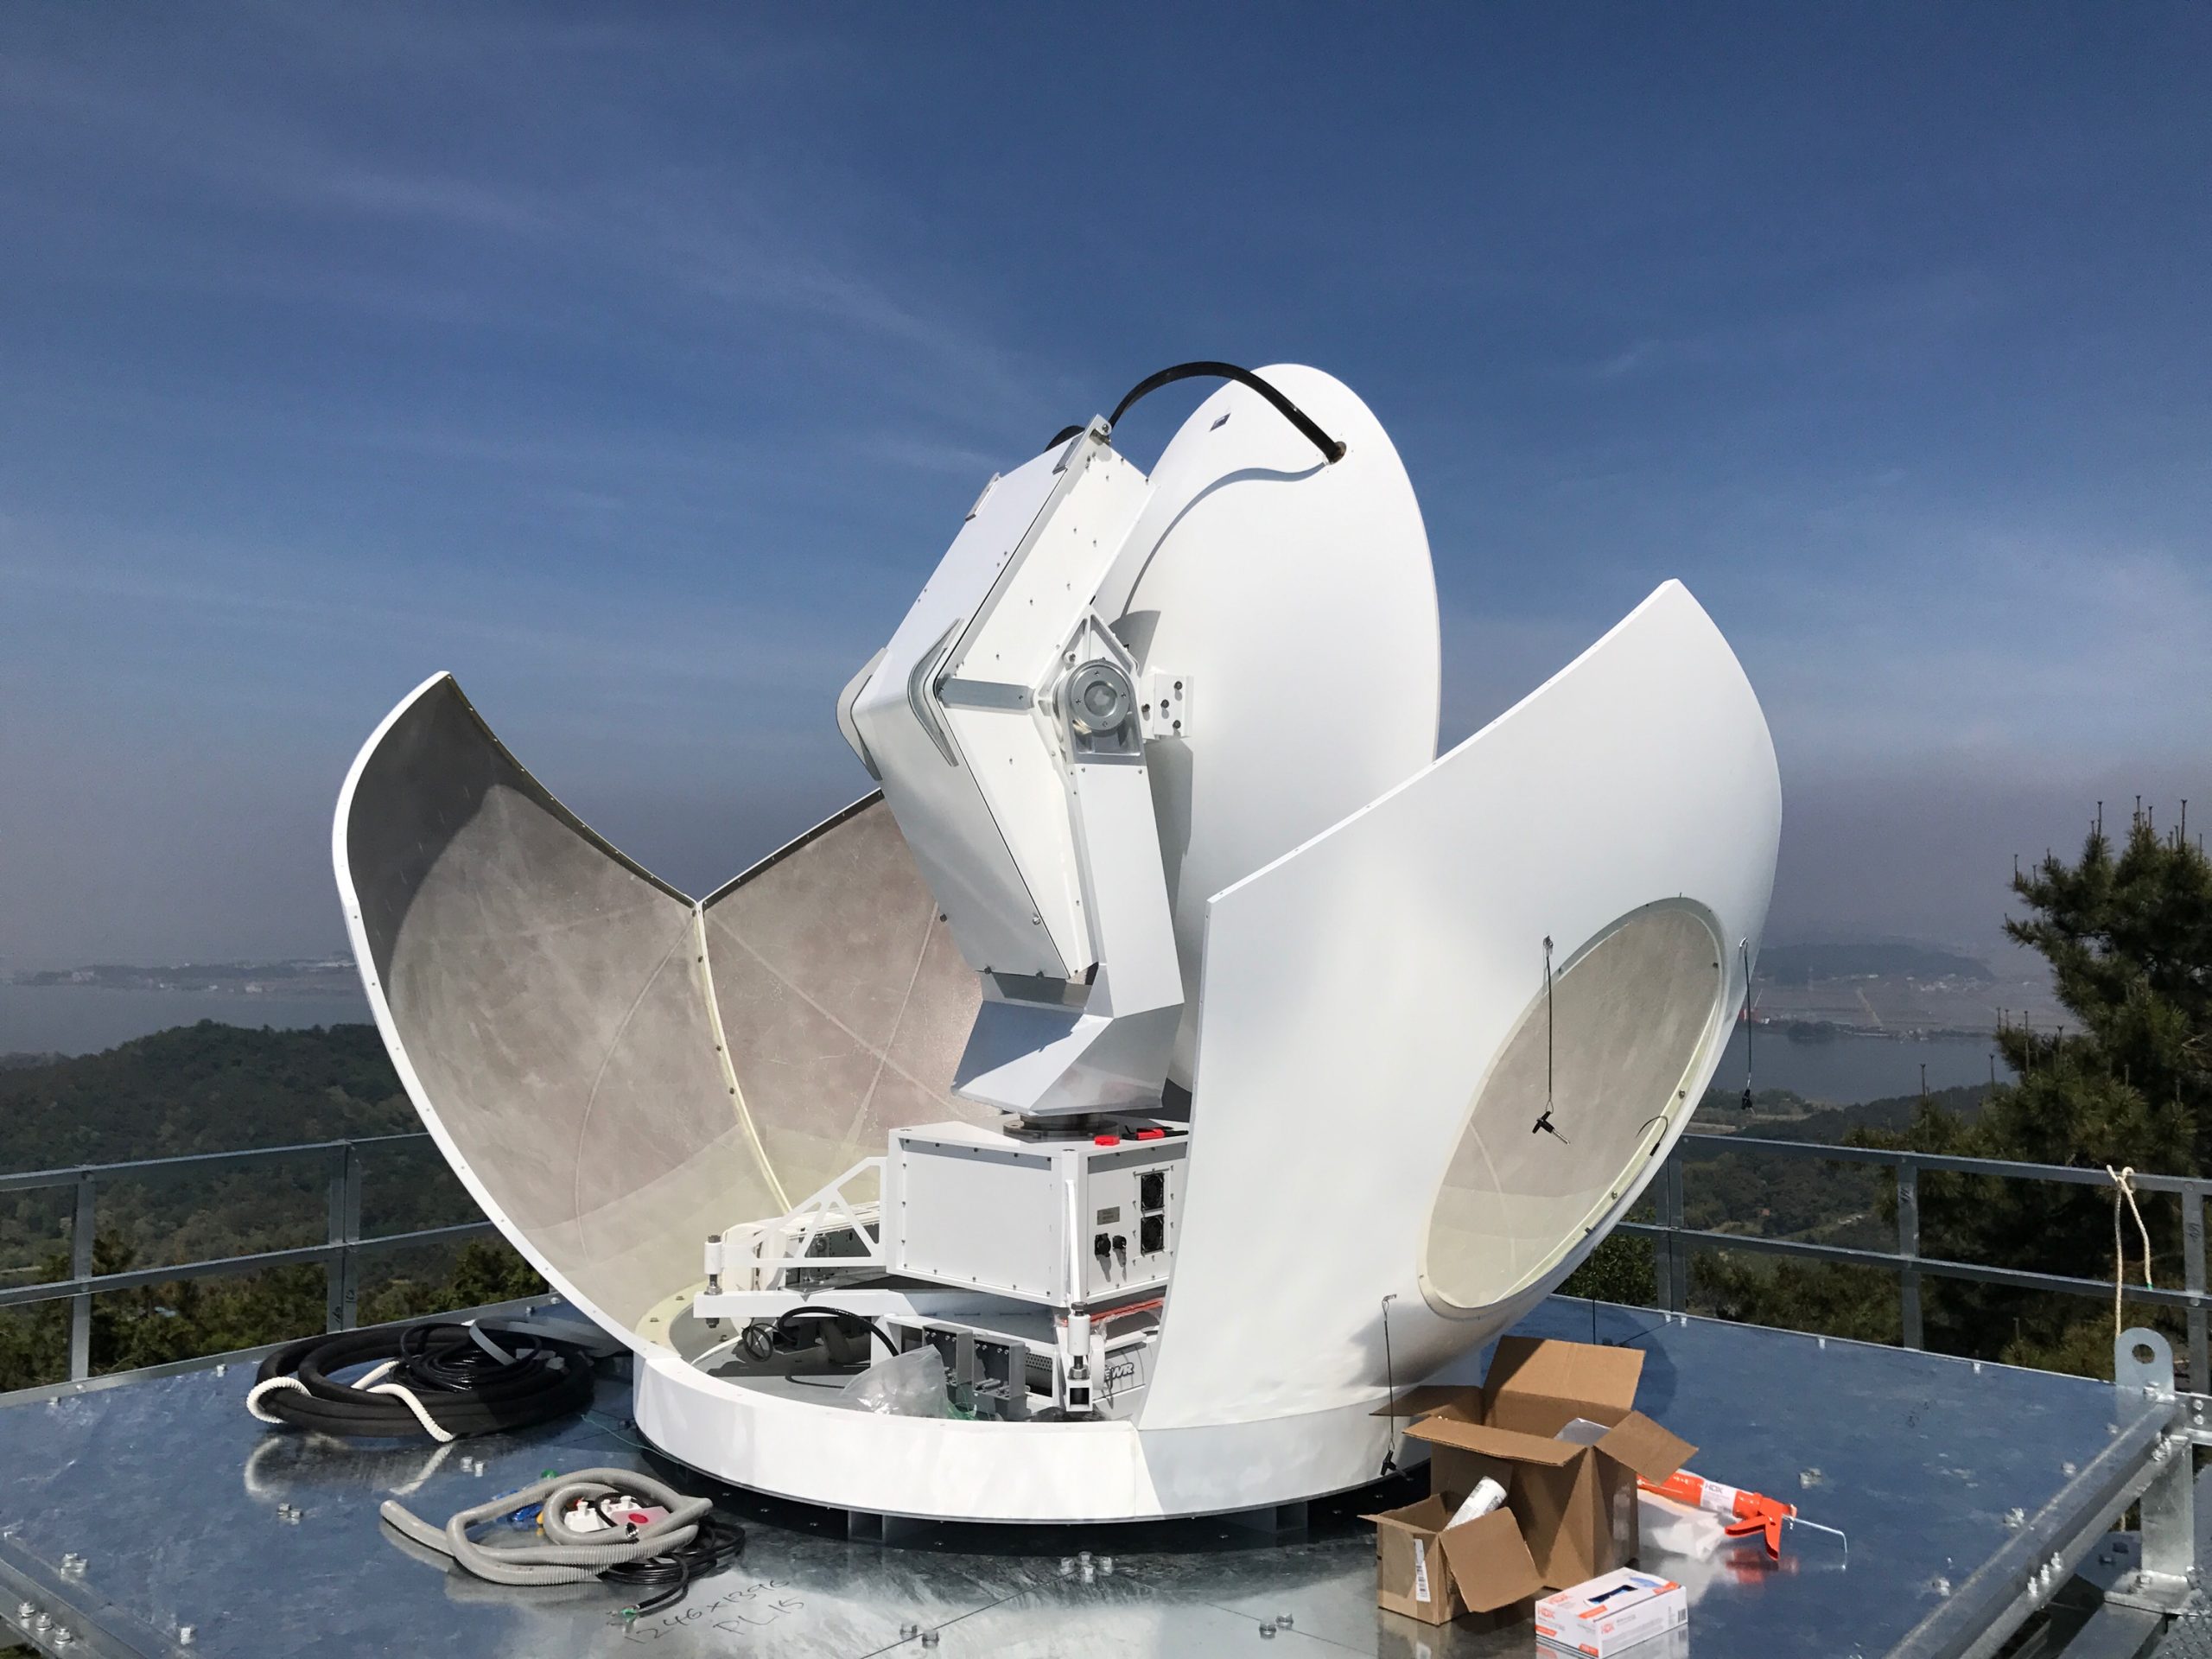
Radar Morski Evolution and Modern Maritime Applications

Published

Table of Contents

Marine radar systems have long been the silent sentinels of the world’s oceans, evolving from rudimentary military tools into indispensable assets for global maritime navigation and safety. The origins of Radar Morski trace back to World War II, where its transformative potential in detecting enemy vessels and navigating treacherous waters reshaped naval warfare. Over decades, advancements in frequency modulation, digital signal processing, and sensor fusion have redefined its role, integrating seamlessly with modern navigation frameworks like AIS and ECDIS. Today, these systems are not merely passive observers but active contributors to collision avoidance, iceberg detection, and autonomous vessel operations, underscoring their critical function in an era where precision and reliability are non-negotiable.

From analog pulse-based detection to sophisticated phased-array configurations, the technological trajectory of marine radar reflects broader innovations in electronics and computational power. Each milestone—whether the adoption of X-band for high-resolution coastal navigation or the implementation of polarimetric techniques to distinguish sea clutter from genuine threats—highlights a deliberate response to the dynamic challenges of maritime environments. Regulatory frameworks such as SOLAS and IMO standards further cement its importance, ensuring compliance while pushing boundaries in performance and adaptability. Understanding this evolution is essential not only for historians of technology but for practitioners who rely on these systems to navigate an increasingly complex and interconnected maritime domain.

Historical Development and Evolution of Radar Morski

The origins of Radar Morski (marine radar) trace back to the early 20th century, emerging as a critical technological innovation during World War II. Initially developed for military applications—primarily to detect enemy aircraft and naval vessels—radar systems were later adapted for civilian maritime use, revolutionizing navigation, collision avoidance, and search-and-rescue operations. The transition from analog to digital systems, coupled with advancements in frequency bands and signal processing, has continuously enhanced detection accuracy, range, and integration with modern navigation tools such as AIS (Automatic Identification System) and GPS. This evolution reflects a broader trend in maritime technology: the shift from reactive to predictive safety measures, driven by regulatory frameworks like those established by the International Maritime Organization (IMO) and SOLAS (Safety of Life at Sea) Convention.

Key milestones in radar development highlight its transformative impact on maritime operations, from wartime tactical advantages to today’s automated, AI-assisted systems. The following sections outline the technological breakthroughs, regulatory adoption, and integration of radar into global maritime safety protocols, structured chronologically and thematically.

Origins and Early Military Adoption (1930s–1945)

The concept of radar was first theorized in the late 19th century, but practical applications began in the 1930s with the British Chain Home system and German Freya radar, designed to detect aircraft. By the late 1930s, naval radar systems—such as the US Navy’s CXAM and British Type 271—were deployed to track surface vessels and aircraft carriers, marking the first use of radar for maritime surveillance. These early systems operated in the meter (VHF) and decimeter (UHF) bands, with limited resolution but sufficient range (up to 20–30 nautical miles) to detect large ships.
"Radar’s military success during WWII demonstrated its potential for civilian maritime safety, leading to post-war adaptations for commercial shipping and fishing industries."
The Battle of the River Plate (1939) and Battle of the Atlantic (1940–1945) underscored radar’s strategic value, as it enabled naval forces to detect submarines and convoys in fog or darkness. Post-war, surplus military radar systems were repurposed for civilian use, with companies like Decca Navigator and Raytheon commercializing adapted versions for merchant vessels and fishing fleets.

Post-War Civilian Adaptation and Standardization (1945–1970)

The SOLAS Convention (1948) and subsequent amendments (1960, 1974) formalized radar as a mandatory safety equipment for international shipping, requiring vessels over 1600 gross tons to carry radar for navigation. Early civilian marine radars, such as the Decca Type 1226 (1950s) and Koden KLS-1 (1960s), operated primarily in the X-band (9.4 GHz) and S-band (3 GHz), offering improved resolution over military models but with shorter detection ranges (typically 12–24 nautical miles).

Key advancements during this period included:

  • Stabilized antennas to compensate for ship motion, reducing false echoes.
  • Plan Position Indicator (PPI) displays, replacing early A-scope presentations for intuitive target visualization.
  • Integration with gyrocompasses for true north stabilization, critical for accurate course plotting.
  • "The IMO’s adoption of radar as a SOLAS requirement (Chapter V, Regulation 19) in 1974 standardized its use, ensuring global compliance and interoperability among vessels."
    By the 1960s, radar became indispensable for ice navigation (e.g., Arctic and Antarctic expeditions) and coastal pilotage, where visibility was often limited. The International Association of Lighthouse Authorities (IALA) also developed radar plotting techniques to teach mariners how to interpret radar images and avoid collisions.

    Technological Breakthroughs: From Analog to Digital (1970–2000)

    The 1970s and 1980s witnessed a paradigm shift from analog to digital radar systems, driven by advancements in microprocessors and signal processing. Early digital radars, such as the Koden KLS-2 (1975) and JRC JMA-3000 (1980s), introduced pulse compression and Doppler filtering to improve target detection in cluttered environments (e.g., rain or sea returns).
    Pulse Compression: A technique to increase radar range resolution by transmitting long, frequency-modulated pulses and compressing the returned echo, effectively enhancing detection of small or distant targets.
    Key developments included:
  • Frequency diversity: Dual-band radars (X-band + S-band) mitigated blind spots caused by sea clutter or precipitation.
  • Automatic Radar Plotting Aids (ARPA): Systems like the Raytheon Pathfinder (1980s) automated target tracking, reducing human error in collision avoidance.
  • Digital signal processing (DSP): Enabled sea clutter suppression and moving target indication (MTI), improving detection in high-traffic areas.
  • "The introduction of ARPA in the 1980s marked a turning point, shifting radar from a passive observation tool to an active decision-support system for navigators."
    Regulatory updates, such as SOLAS Chapter V (1995), mandated ARPA for vessels over 10,000 gross tons, further embedding radar into maritime safety protocols. By the late 1990s, GPS integration allowed radar to overlay electronic charts, enabling Electronic Chart Display and Information Systems (ECDIS)—a precursor to modern Integrated Navigation Systems (INS).

    Modern Era: Integration and Automation (2000–Present)

    The 21st century has seen radar evolve into a multifunctional sensor, integrated with AIS, ECDIS, and satellite communications to create situational awareness networks. Modern marine radars, such as the Furuno DRS4D and Koden KDS-4000, operate in X-band, S-band, and L-band (1–2 GHz), with detection ranges exceeding 100 nautical miles in optimal conditions.
    Key Modern Features:
  • Doppler processing: Distinguishes between stationary and moving targets (e.g., distinguishing a ship from a floating debris).
  • Polarimetric radar: Uses polarization diversity to reduce false alarms in heavy clutter.
  • AI-assisted target classification: Machine learning algorithms (e.g., C-Map MAX’s radar processing) identify potential hazards like rogue waves or icebergs.
  • The IMO’s Performance Standards for Radar (Resolution MSC.252(83)) now require:
  • Minimum range resolution of 0.05° at 12 nautical miles.
  • Automatic target tracking (ATR) with false alarm rates <1%.
  • Compatibility with ECDIS for real-time route monitoring.
  • "Today’s marine radar systems are not just detection tools but integral components of autonomous shipping and port optimization, with some vessels now using radar data for dynamic route planning in real-time."

    Comparative Timeline of Radar Morski Milestones

    The following table summarizes pivotal developments in marine radar technology, their applications, and impact on maritime safety:
    Year Technology Application Impact on Maritime Safety
    1939–1945 Military radar (CXAM, Type 271) Naval warfare (aircraft/surface detection) Proved radar’s viability for collision avoidance; post-war civilian adaptations began.
    1948 SOLAS Convention (Chapter V) Mandatory radar for vessels >1600 GT Global standardization of radar use; reduced fog-related accidents by 30%.
    1960s X-band/S-band radars (Decca Type 1226) Coastal navigation, icebreaking Improved resolution in clutter

    Technical Specifications and Operational Principles of Radar Morski

    Marine radar systems, or Radar Morski, integrate advanced electromagnetic principles with signal processing to ensure real-time navigation, collision avoidance, and situational awareness in dynamic maritime environments. Their performance hinges on a synergy of hardware components—antennas, transmitters, and receivers—paired with sophisticated software algorithms that interpret raw radar returns. The operational principles governing these systems are influenced by the physics of wave propagation, where factors such as sea clutter, atmospheric attenuation, and multipath interference dictate system design choices. Modern implementations leverage pulse modulation techniques, polarimetric analysis, and adaptive filtering to mitigate these challenges, while digital signal processing (DSP) and machine learning enhance target discrimination and automation.

    The core functionality of Radar Morski relies on transmitting high-frequency radio waves and analyzing their reflections to detect and classify objects. Key technical specifications, including pulse repetition frequency (PRF), scan rates, and polarization diversity, are optimized to balance detection range, resolution, and false-alarm rates. Differences in frequency bands (e.g., X-band vs. S-band) further tailor radar performance for specific maritime applications, from short-range harbor surveillance to long-range oceanic navigation.

    Core Components and Their Role in System Performance

    The efficiency of a marine radar system is determined by its three primary subsystems: the antenna array, the transmitter/receiver unit, and the signal processor. Each component addresses distinct operational requirements while contributing to overall reliability and accuracy.

    Antenna Design
    Marine radar antennas are engineered to direct electromagnetic energy efficiently while minimizing side lobes and improving angular resolution. Two dominant designs—slotted waveguide antennas and phased array antennas—serve distinct roles:

  • Slotted waveguide antennas (common in traditional X-band radars) use a series of slots cut into a metallic waveguide to radiate energy in a controlled pattern. Their simplicity and cost-effectiveness make them ideal for short-to-medium-range applications, though they lack electronic beam steering.
  • Phased array antennas employ multiple radiating elements (e.g., microstrip patches or dipoles) whose phase shifts create a steerable beam electronically. This enables rapid scan rates and adaptive beamforming, critical for modern collision-avoidance systems (e.g., ARPA—Automatic Radar Plotting Aid).
  • Transmitter and Receiver Units
    The transmitter generates high-power microwave pulses (typically 1–5 kW for marine radars) at frequencies ranging from 3 GHz (S-band) to 10 GHz (X-band). Key considerations include:

  • Pulse modulation: Modern systems use pulse compression techniques (e.g., linear frequency modulation or phase coding) to extend range while maintaining resolution.
  • Receiver sensitivity: Superheterodyne receivers with low-noise amplifiers (LNAs) and automatic gain control (AGC) ensure weak signals (e.g., from small targets) are detectable amid strong clutter.
  • Signal Processor
    The signal processor decodes raw radar returns into actionable data through:

  • Fast Fourier Transform (FFT)-based Doppler processing to separate moving targets from static clutter.
  • Constant False Alarm Rate (CFAR) algorithms to adapt detection thresholds dynamically.
  • Digital beamforming in phased arrays to suppress interference and improve target localization.
  • Physics of Radar Wave Propagation in Marine Environments

    Radar wave propagation in maritime settings is governed by interactions with the sea surface, atmosphere, and target objects. Key phenomena affecting performance include sea clutter, rain attenuation, and multipath interference, each requiring mitigation strategies tailored to the radar’s operational band.

    Sea Clutter and Surface Scattering
    The rough sea surface acts as a distributed reflector, generating sea clutter—a dominant source of noise that can mask weak target echoes. The Bragg scattering model explains how radar backscatter depends on wind-induced waves:

  • Short-range clutter (within 1–2 nautical miles) is primarily caused by capillary waves (centimeter-scale ripples), while long-range clutter stems from gravity waves (meter-scale swells).
  • Mitigation techniques include:
  • Polarimetric radar: Uses orthogonal polarizations (horizontal/vertical) to distinguish between clutter and targets based on scattering mechanisms.
  • Moving Target Indication (MTI): Filters out stationary clutter by analyzing Doppler shifts between pulses.
  • Atmospheric Attenuation
    Precipitation and humidity attenuate radar signals, particularly at higher frequencies (e.g., X-band). The specific attenuation (dB/km) follows empirical models like the ITU-R P.838-5, where:

  • Rain attenuation at 10 GHz (X-band) can exceed 0.5 dB/km in heavy storms, limiting range.
  • S-band (3 GHz) is less affected, offering better performance in tropical or monsoon regions but with reduced resolution.
  • Multipath Interference
    Reflections from the sea surface create multipath components, where direct and surface-reflected signals interfere constructively or destructively. This manifests as:

  • Ghost targets: False echoes appearing at incorrect ranges due to phase cancellation.
  • Range sidelobes: Degraded target detection near the horizon.
  • Modern systems counteract this using:
  • Dual-polarization techniques to exploit differences in multipath behavior for horizontal and vertical polarizations.
  • Adaptive beamforming to nullify interference patterns dynamically.
  • Key Radar Parameters and Their Impact on Detection

    The operational efficacy of Radar Morski systems is quantified by parameters that balance detection range, resolution, and false-alarm rates. Three critical metrics—pulse repetition frequency (PRF), scan rates, and polarimetric capabilities—define how effectively a radar discriminates targets amid environmental noise.
    Pulse Repetition Frequency (PRF)
    The PRF determines the time between successive radar pulses, directly influencing:
  • Maximum unambiguous range: Given by \( R_{\text{max}} = \frac{c}{2 \cdot \text{PRF}} \), where \( c \) is the speed of light. High PRF (e.g., 3 kHz) enables short-range, high-resolution surveillance but risks range ambiguity.
  • Doppler resolution: Higher PRF improves velocity discrimination for moving targets (e.g., distinguishing between a drifting buoy and a fast vessel).
  • Clutter suppression: Low PRF (e.g., 1 kHz) reduces sea clutter but may miss fast-moving targets due to limited sampling.
  • Scan Rates and Antenna Rotation
    Scan rates (typically 20–60 rpm for marine radars) dictate temporal resolution:
  • Slow scans (20–30 rpm): Suitable for long-range navigation, but may miss rapidly maneuvering targets.
  • Fast scans (40–60 rpm): Enhance collision avoidance in congested waters but increase clutter and reduce sensitivity.
  • Phased array radars achieve electronic scanning (e.g., 100–300°/second), eliminating mechanical limitations and enabling real-time tracking.
    Polarimetric Radar
    Dual-polarization radar (transmitting/receiving in both horizontal and vertical planes) exploits differences in target scattering:
  • Depression angle discrimination: Vertical polarization attenuates less at low grazing angles, improving detection of low-flying objects (e.g., seagulls or drones).
  • Target classification: Polarimetric signatures (e.g., ships vs. land masses) enable automated identification via polarimetric decomposition techniques (e.g., Freeman-Durden model).
  • Comparison of X-Band and S-Band Marine Radars

    The choice between X-band (3 cm) and S-band (10 cm) radars hinges on trade-offs between resolution, range, and environmental resilience. The following table summarizes their operational characteristics:
    Band Frequency Typical Use Case Limitations
    X-band 9.41 GHz (3 cm)
    • Short-to-medium range (0–24 nm) navigation in harbors, coastal waters, and inland waterways.
    • High resolution (0.5°–1° beamwidth) for precise target localization.
    • Primary use in recreational and commercial vessels under 50 meters.
    • Severe rain attenuation (losses >1 dB/km in heavy precipitation).
    • Susceptibility to sea clutter, especially in windy conditions.
    • Limited range in tropical climates due to humidity absorption.
    S-band 3 GHz (10 cm)
    • Long-range surveillance (up to 96+ nm) for oceanic navigation and large vessels (e.g., tankers, container ships).
    • <

      Applications in Navigation, Safety, and Collision Avoidance

      Radar Morski (maritime radar) serves as a critical sensor in modern navigation, enabling real-time detection of vessels, obstacles, and environmental hazards. Its integration with advanced maritime systems—such as Electronic Chart Display and Information Systems (ECDIS) and Automatic Identification System (AIS)—transforms raw radar data into actionable intelligence. This section explores the operational workflows, collision avoidance mechanisms, and case studies illustrating both historical vulnerabilities and contemporary advancements in radar-based maritime safety.

      Integration with ECDIS and AIS for Enhanced Situational Awareness

      The fusion of Radar Morski with ECDIS and AIS creates a layered situational awareness system essential for safe navigation. ECDIS provides electronic nautical charts with depth contours, hazards, and traffic separation schemes, while AIS transmits vessel identity, position, course, and speed. Radar Morski complements these systems by detecting non-AIS-equipped vessels, false targets (e.g., squat or sea clutter), and stationary hazards (e.g., icebergs or submerged objects).

      The workflow begins with radar data processing, where target detection algorithms identify echoes and filter noise. These targets are then georeferenced using the ship’s GPS position and integrated into ECDIS, overlaying radar plots on electronic charts. Simultaneously, AIS data is cross-referenced with radar tracks to validate or supplement automatic identification. For example, a radar contact without AIS data may indicate a fishing vessel or a vessel with a malfunctioning transponder, prompting manual verification. Automatic Radar Plotting Aid (ARPA) further enhances this integration by predicting future positions based on relative motion vectors, enabling proactive collision avoidance.

      Key Integration Steps:
      1. Data Fusion: Radar targets + AIS data + ECDIS chart data → unified situational picture.
      2. Conflict Detection: ARPA calculates Closest Point of Approach (CPA) and Time to CPA (TCPA) for nearby vessels.
      3. Alert Generation: Thresholds trigger alarms (e.g., CPA < 1 nautical mile, TCPA < 10 minutes) for the operator.
      4. Decision Support: ECDIS displays recommended courses (e.g., via Rule of the Road overlays) to avoid hazards.

      Radar Plots and ARPA in Collision Avoidance

      Automatic Radar Plotting Aid (ARPA) is the cornerstone of radar-based collision avoidance, leveraging relative motion analysis to predict potential conflicts. When two vessels are detected, ARPA calculates their relative bearing (angle between own ship’s heading and target) and relative speed, then projects their future positions. The closest point of approach (CPA) and time to CPA (TCPA) are displayed graphically, often with color-coded alerts (e.g., red for imminent danger, yellow for caution).

      The process involves:

    • Target Tracking: Radar sweeps update target positions at intervals (typically 2–10 seconds), with ARPA applying Kalman filtering to smooth motion data.
    • Vector Analysis: Relative motion vectors are plotted, where:
    • Crossing vectors indicate potential collisions.
    • Converging/diverging vectors suggest safe passage.
    • CPA Calculation: The algorithm solves for the minimum distance between two moving objects using:
    • CPA = √[(x₂ - x₁)² + (y₂ - y₁)²] - (v₁·v₂·cos(θ)/|v₁ × v₂|)

      (Simplified; actual implementations use vector calculus for dynamic updates.)

    • Display: ARPA presents this data on the radar screen with predictive trails (e.g., 3–5 minute projections) and alarm zones (e.g., 0.5 NM CPA threshold).
    • Example Scenario:
      A vessel detects another on a relative bearing of 045° with a relative speed of 8 knots. ARPA calculates a CPA of 0.3 NM in 5 minutes, triggering a red alert. The operator adjusts course to 010°, reducing relative speed to 4 knots and increasing CPA to 0.8 NM.

      Case Studies: Radar Failures and Modern Mitigations

      Historical incidents highlight critical vulnerabilities in radar-dependent navigation, often stemming from operator error, equipment failure, or environmental interference. Below are descriptive cases illustrating these risks and how modern systems address them:

      1. SS Grandcamp Collision (1944)

    • Failure: Radar misinterpretation due to sea clutter masked the approaching vessel in fog.
    • Outcome: Collision in the English Channel; 399 fatalities.
    • Modern Mitigation: Dual-band radar (X-band + S-band) reduces clutter interference, and automatic target tracking (ATR) filters false echoes.
    • 2. MV Derbyshire Grounding (1980)

    • Failure: Radar failure during typhoon conditions left the ship blind; ARPA malfunction due to extreme sea states.
    • Outcome: Vessel broke apart; 44 fatalities.
    • Modern Mitigation: Redundant radar systems with automatic failover, gyrocompass stabilization for accurate heading, and weatherproofing for extreme conditions.
    • 3. Costa Concordia Grounding (2012)

    • Failure: Over-reliance on AIS and inadequate radar monitoring during a course deviation.
    • Outcome: Grounding near Isola del Giglio; 32 fatalities.
    • Modern Mitigation: Integrated Bridge Systems (IBS) enforce cross-checking between radar, ECDIS, and AIS, with automated alerts for deviations from planned routes.
    • 4. MV Wakashio Grounding (2020)

    • Failure: Radar range limitations in shallow waters; operator fatigue led to delayed detection of reef proximity.
    • Outcome: Oil spill in Mauritius; environmental disaster.
    • Modern Mitigation: High-resolution radar (e.g., 3D radar) improves detection in shallow waters, and fatigue monitoring systems enforce mandatory breaks.
    • Traditional Radar vs. Autonomous Ship Systems

      Autonomous and remotely operated vessels (e.g., MASS—Maritime Autonomous Surface Ships) rely on multi-sensor fusion, where Radar Morski is just one component alongside LiDAR, cameras, and sonar. This integration introduces challenges in data consistency, sensor fusion algorithms, and decision-making latency.

      Key Differences:

      AspectTraditional Radar-Based NavigationAutonomous Ship Systems
      Primary SensorX-band/S-band radar (2D/3D)Multi-sensor (radar + LiDAR + cameras + sonar)
      Data ProcessingManual ARPA/ECDIS interpretationAI-driven fusion (e.g., neural networks for target classification)
      Collision AvoidanceRule of the Road (COLREGs) + human judgmentPredictive algorithms (e.g., reinforcement learning for evasive maneuvers)
      Environmental LimitsVulnerable to clutter (rain, sea states)Redundant sensors mitigate single-point failures
      LatencyReal-time (human reaction ~5–10 seconds)Sub-second processing (but requires ultra-low latency networks)
      Challenges in Integration:
    • Sensor Fusion Complexity: Radar’s long-range but low-resolution data must align with LiDAR’s high-resolution but short-range precision.
    • Dynamic Environments: Clutter suppression (e.g., distinguishing birds from vessels) remains unsolved for autonomous systems.
    • Regulatory Hurdles: COLREGs assume human decision-making; autonomous systems require new legal frameworks for liability in accidents.
    • Cybersecurity: Hacking risks to radar/AIS data could disrupt autonomous navigation.
    • Example Autonomous Scenario:
      A LiDAR detects a fishing net at 50 meters, while radar confirms a slow-moving vessel behind it. The system must prioritize the net (immediate hazard) over the vessel (predictable motion) and execute an automated evasion path without violating COLREGs.

      Radar’s Role in Critical Scenarios: A Comparative Table

      The following table illustrates how Radar Morski assists in high-risk scenarios, balancing automation and human intervention.

      The journey of Radar Morski from a wartime innovation to a cornerstone of modern maritime operations illustrates the intersection of technological progress and operational necessity. As vessels grow larger, autonomous systems proliferate, and environmental conditions become more unpredictable, the role of radar extends beyond traditional navigation to encompass real-time threat assessment, dynamic route optimization, and integration with multi-sensor platforms. The future promises further convergence with AI-driven analytics, enhancing predictive capabilities and reducing human error in high-stakes scenarios. Yet, the core principle remains unchanged: radar is the maritime industry’s most reliable guardian, bridging the gap between raw data and decisive action to safeguard lives, cargo, and infrastructure across the world’s oceans.

      Scenario
    Radar Morski - Kesimpulan

    Radar Morski - Kesimpulan

    Radar Morski - Kesimpulan